👋 About Me
I am a Ph.D. student at the School of Engineering Science / Institute of Humanoid Robotics, University of Science and Technology of China (USTC), supervised by Prof. Shiwu Zhang and Dr. Wei Gao. I received my Bachelor’s and Master’s degrees from Hefei University of Technology (HFUT).
My research focuses on humanoid robotics and motor control, applying advanced control theory to robotic systems — including model-based and learning-based locomotion control for humanoid robots, parameter identification, state estimation, and motor drives. I have published several academic papers (including co-authored works), listed below.

🎓 Education
- 2023.09 - Present
University of Science and Technology of China (USTC), Hefei, China
Ph.D. Student, School of Engineering Science / Institute of Humanoid Robotics - 2019.09 - 2022.06
Hefei University of Technology (HFUT), Hefei, China
M.Eng. in Control Science and Engineering - 2015.09 - 2019.07
Hefei University of Technology (HFUT), Hefei, China
B.Eng. in Automation
📝 Publications & Patents
Chinese Journal Papers
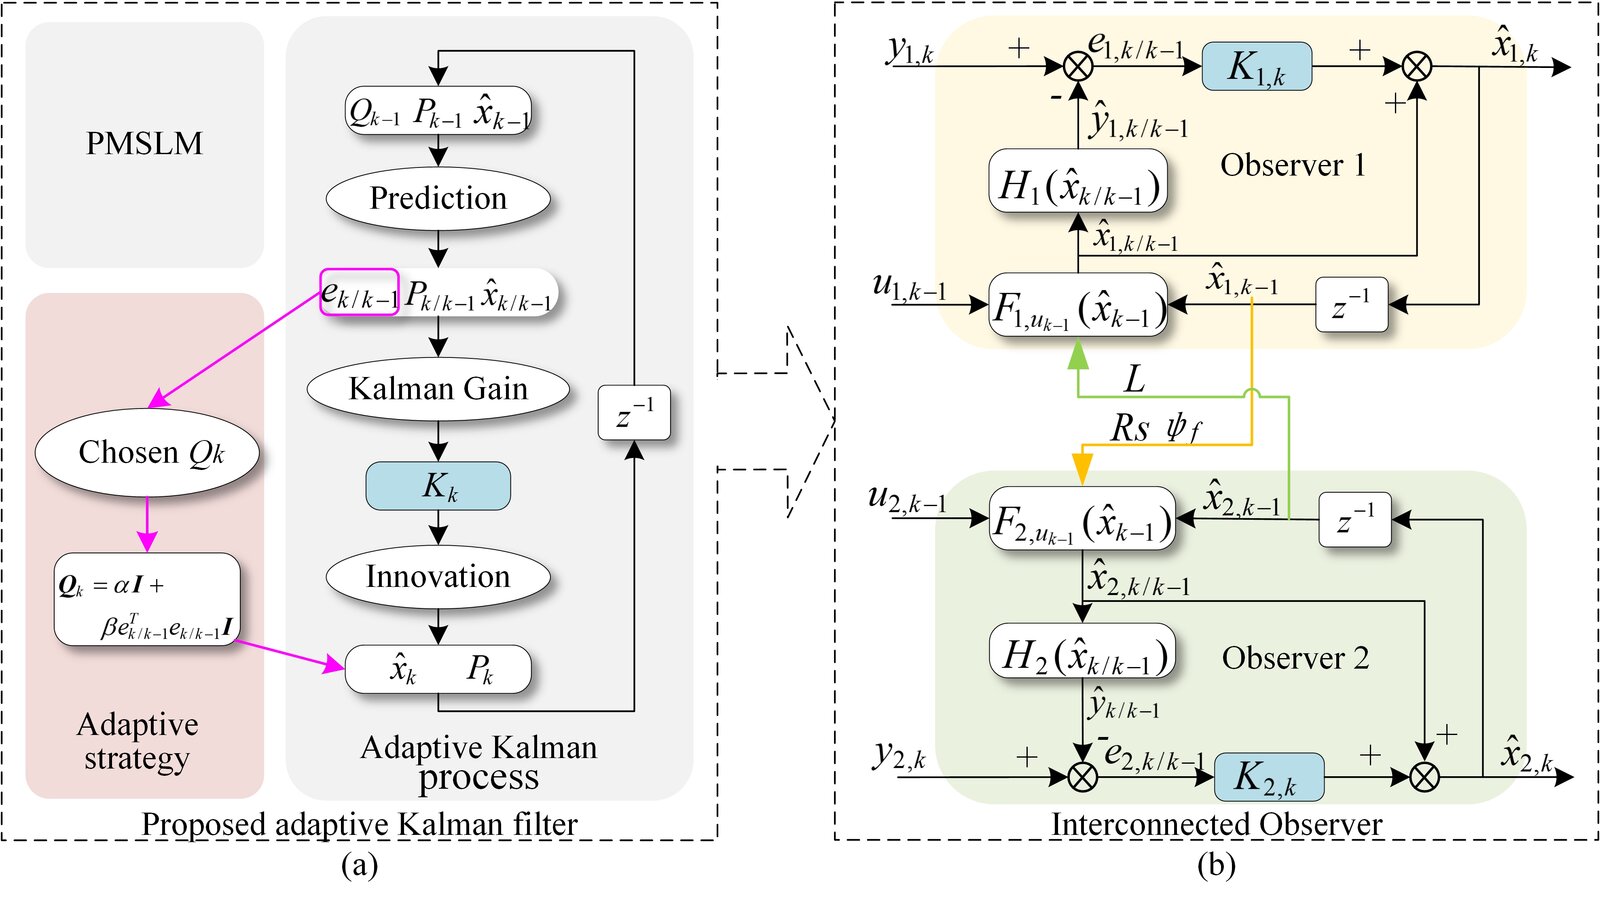
Xiaohu Zhang, Jiwen Zhao et al.
“High Precision Anti-Disturbance Online Multi-Parameter Identification for Permanent Magnet Synchronous Linear Motor Based on Adaptive Interconnected Extended Kalman Observer,” Proceedings of the CSEE, 2022, 42(12): 4571-4581.
Annual Excellent Paper of CSEE (Top 5%)High Impact Paper of CNKIEI
English Papers
- arXiv 2026
T. Huang, M. Zhao, Y. Gao, F. Yuan, J. Gu,X. Zhang, D. Zhao, S. Yan, Y. Wang, W. Gao and S. Zhang
“Bionic Human-Motion Style Transfer for Physically Executable Whole-Body Control of Humanoid Robots,” arXiv preprint arXiv:2606.03536, 2026.
arXiv
- arXiv 2026
T. Huang, F. Yuan, J. Gu, S. Fang,X. Zhang, Y. Wang, W. Gao and S. Zhang
“Human2Humanoid: Physics-Aware Cross-Morphology Motion Retargeting for Humanoid Robots,” arXiv preprint arXiv:2606.03476, 2026.
arXiv
- J. Gu, F. Yuan, W. Shi, T. Huang, H. Zhang,
X. Zhang, Y. Wang, W. Gao and S. Zhang
“SKATER: Synthesized Kinematics for Advanced Traversing Efficiency on a Humanoid Robot via Roller Skate Swizzles,” arXiv preprint arXiv:2601.04948, 2026.
arXiv
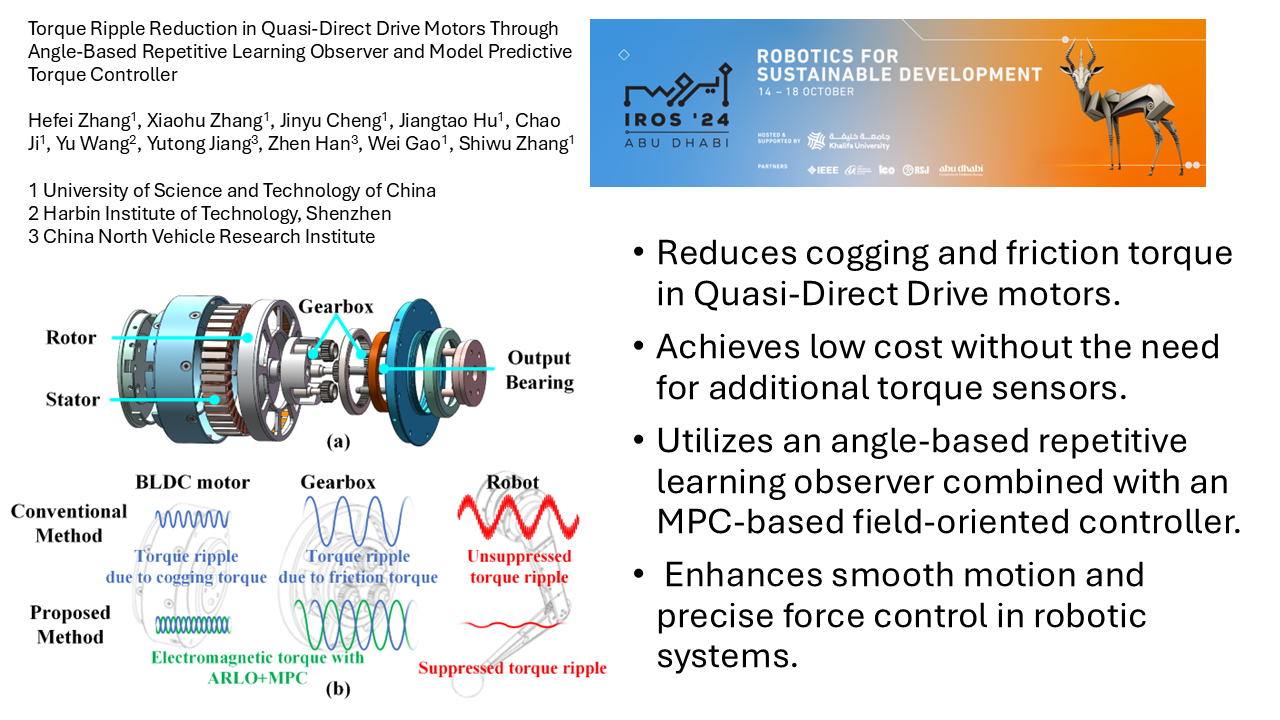
- H. Zhang#,
X. Zhang#, J. Cheng, J. Hu, C. Ji, Y. Wang, Y. Jiang, Z. Han, W. Gao* and S. Zhang*
“Torque Ripple Reduction in Quasi-Direct Drive Motors Through Angle-Based Repetitive Learning Observer and Model Predictive Torque Controller,” 2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Abu Dhabi, United Arab Emirates, pp. 3546-3552.
Co-first authorTop robotics conference, EI
IEEE
- J. Hu, W. Gao,
X. Zhang, J. Cheng and S. Zhang
“Predictive Control of a Spined Quadrupedal Robot Based on a Dual Rigid-Body Model,” 2024 IEEE International Conference on Robotics and Biomimetics (ROBIO), pp. 292-298, 2024.
EI
IEEE
-
T. Wang, Y. Zhu,
X. Zhang, W. Gao and S. Zhang
“A Telepresence Enhancing Method Based on Human Arm Dynamics,” 2024 IEEE International Conference on Robotics and Biomimetics (ROBIO), pp. 1415-1421, 2024.
EI
IEEEResponsible for the hardware system design; along the way I learned PCB design and built two circuit board versions (STM32 and ESP32).
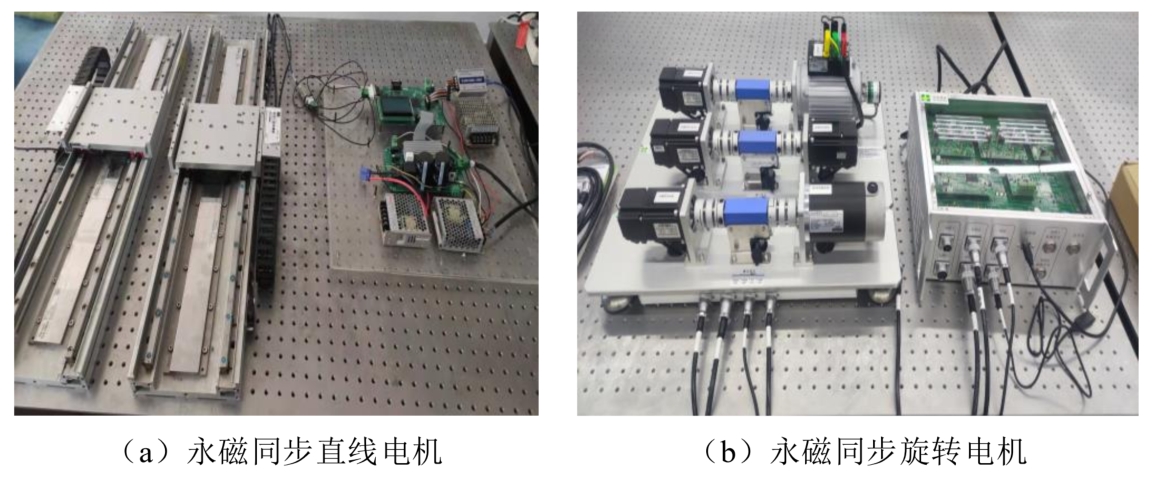
- L. Wang, J. Zhao, X. Yang, Z. Zheng,
X. Zhang, L. Wang
“Robust Deadbeat Predictive Current Regulation for Permanent Magnet Synchronous Linear Motor Drivers With Parallel Parameter Disturbance and Load Observer,” IEEE Transactions on Power Electronics, 2022, 37(7): 7834-7845.
CAS Top, IF: 5.967
DOI
- IEEE TIM 2022
D. Hu, J. Zhao, X. Yang,X. Zhang
“Precision Motion Measurement for Linear Motor Based on FNCC and Phase Difference M-Estimator Robust Regression in a VLSM System,” IEEE Transactions on Instrumentation and Measurement, 2022, 70: 5017310.
SCI, IF: 5.332
DOI
X. Zhang, J. Zhao et al.
“Joint Kalman Observer for Mechanical Multi-parameter Decoupling Estimation of Permanent Magnet Synchronous Linear Motor,” 2021 13th International Symposium on Linear Drives for Industry Applications (LDIA), 2021.
EI
IEEE
- IEEE TII 2020
J. Song, J. Zhao,X. Zhanget al.
“Accurate Demagnetization Faults Detection of Dual-Sided Permanent Magnet Linear Motor Using Enveloping and Time-Domain Energy Analysis,” IEEE Transactions on Industrial Informatics, 2020, 16(10): 6334-6346.
CAS Top, IF: 11.648
Projects
Xiaohu Zhang, both, pocket et al.
“MPC+WBC Based Motion Control for a Full-size Humanoid Robot,” 2024 - Present.
Involved throughout in mechanical design iteration, electrical system design, low-level communication interfaces, and optimization of classical control algorithms.
Patents
- [P03] Locomotion Control Method for Legged Robots
Wei Gao, Zhen Han, Yutong Jiang, Yongming Yue,Xiaohu Zhang, Yu Wang, Shiwu Zhang. Invention Patent, CN202411919748.1, Granted: 2025-01-24, Filed: 2024-12-25. - [P02] Torque Ripple Suppression Method for Quasi-Direct Drive Motors in Robot Joints
Shiwu Zhang,Xiaohu Zhang, Hefei Zhang, Wei Gao. Invention Patent, CN202410747271.7, Under Examination, Filed: 2024-06-11. - [P01] Force Feedback Method and Device for Teleoperation System Based on Vibration Induction
Shiwu Zhang, Yuewei Zhu, Tengda Wang, Wei Gao,Xiaohu Zhang, Yuanzhe Xie. Invention Patent, ZL202410471429.2, Granted: 2024-07-12, Filed: 2024-04-19.
🏅 Honors and Awards
- 2025
Gold Medal, Anhui Province College Students Innovation Competition - 2023
Annual Excellent Paper of CSEE - 2023 - Present Scholarship, University of Science and Technology of China
- 2022 First-Class Scholarship, Hefei University of Technology
- 2018 Second Prize, National University Intelligent Transportation Innovation and Entrepreneurship Competition
🏛️ Academic Conferences
- Hangzhou, China Attended
IROS 2025 - Abu Dhabi, UAE Attended
IROS 2024and gave an oral presentation - Wuhan, China Attended
LDIA 2021and presented a poster - Hefei, China Attended the
World Manufacturing Convention(2019, 2023, 2024) - Shenyang, China Attended the China Robot Science Conference (
CCRS 2019)
💻 Internships
- 2025.09 Intern, a humanoid robotics company, Wuhu, Anhui
- 2022 - 2023 Research Intern, Institute of Advanced Technology, USTC, Hefei, Anhui